Digital file
RB-6 Robot Arm
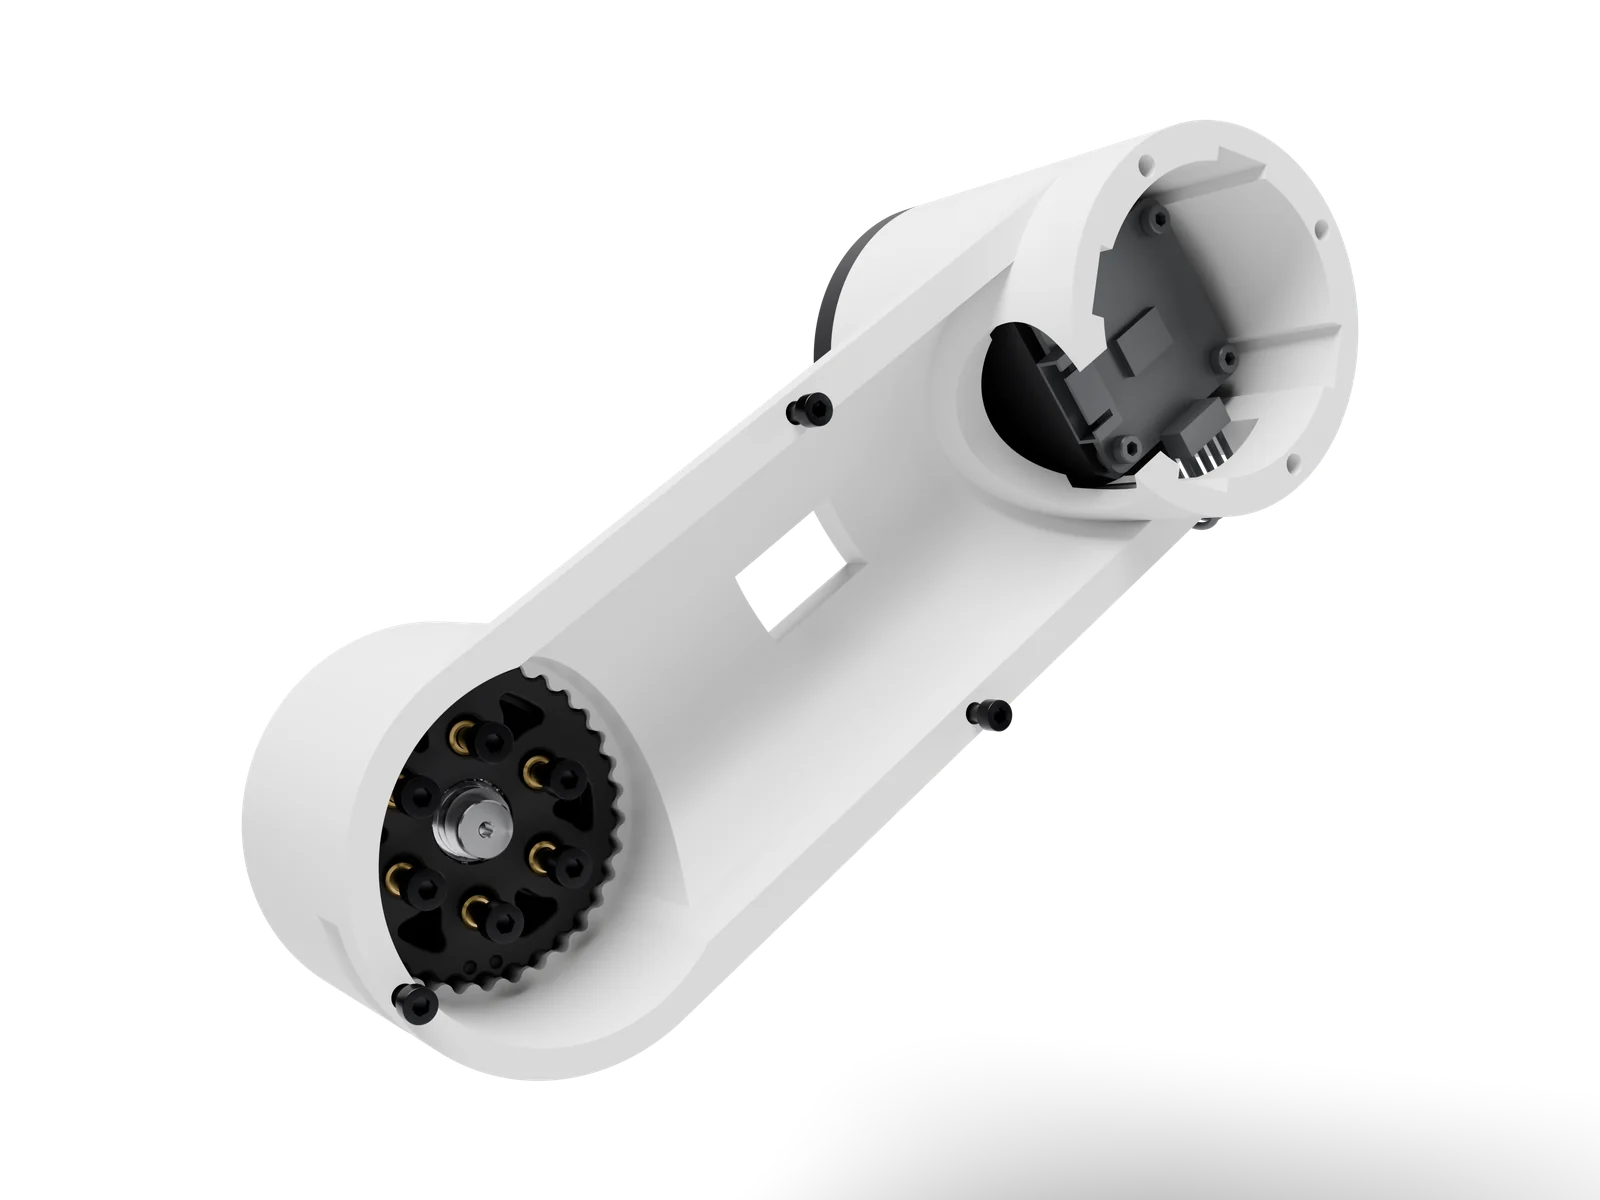
Every printed part of the six-axis arm, NEMA17 mounts and the assembly order.
In developmentDetails

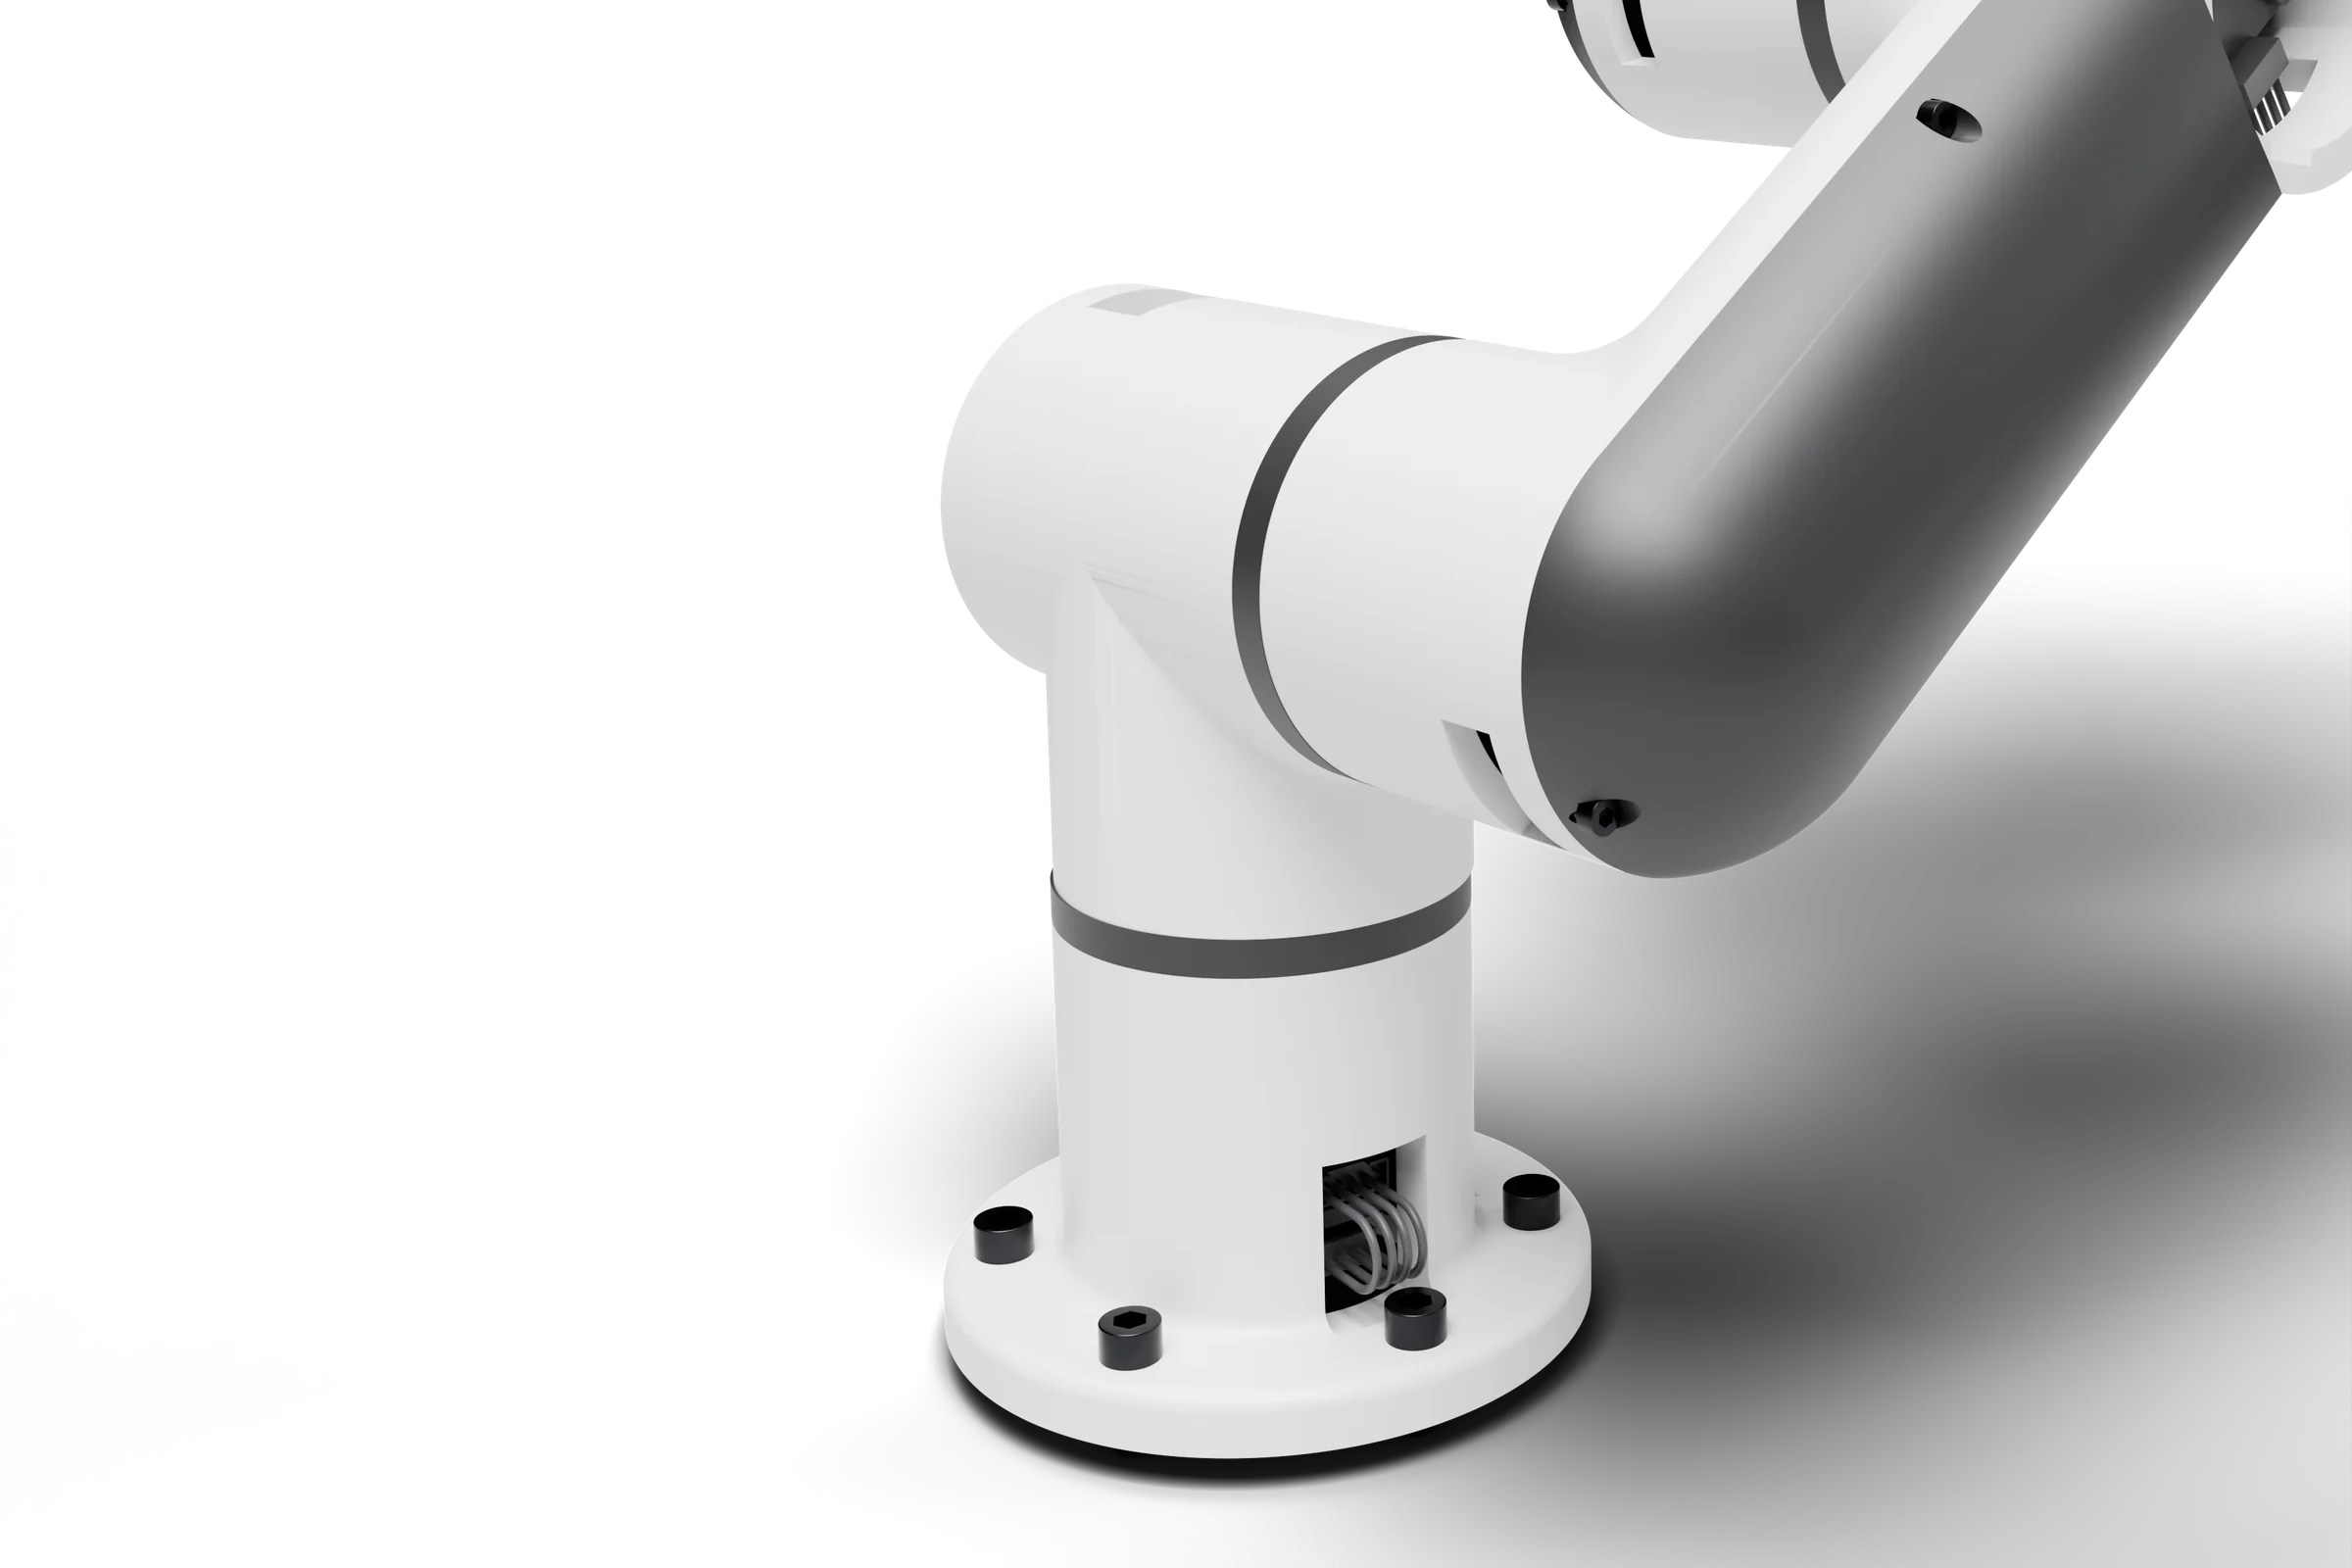 Robot arm In developmentSix axes, every printed part
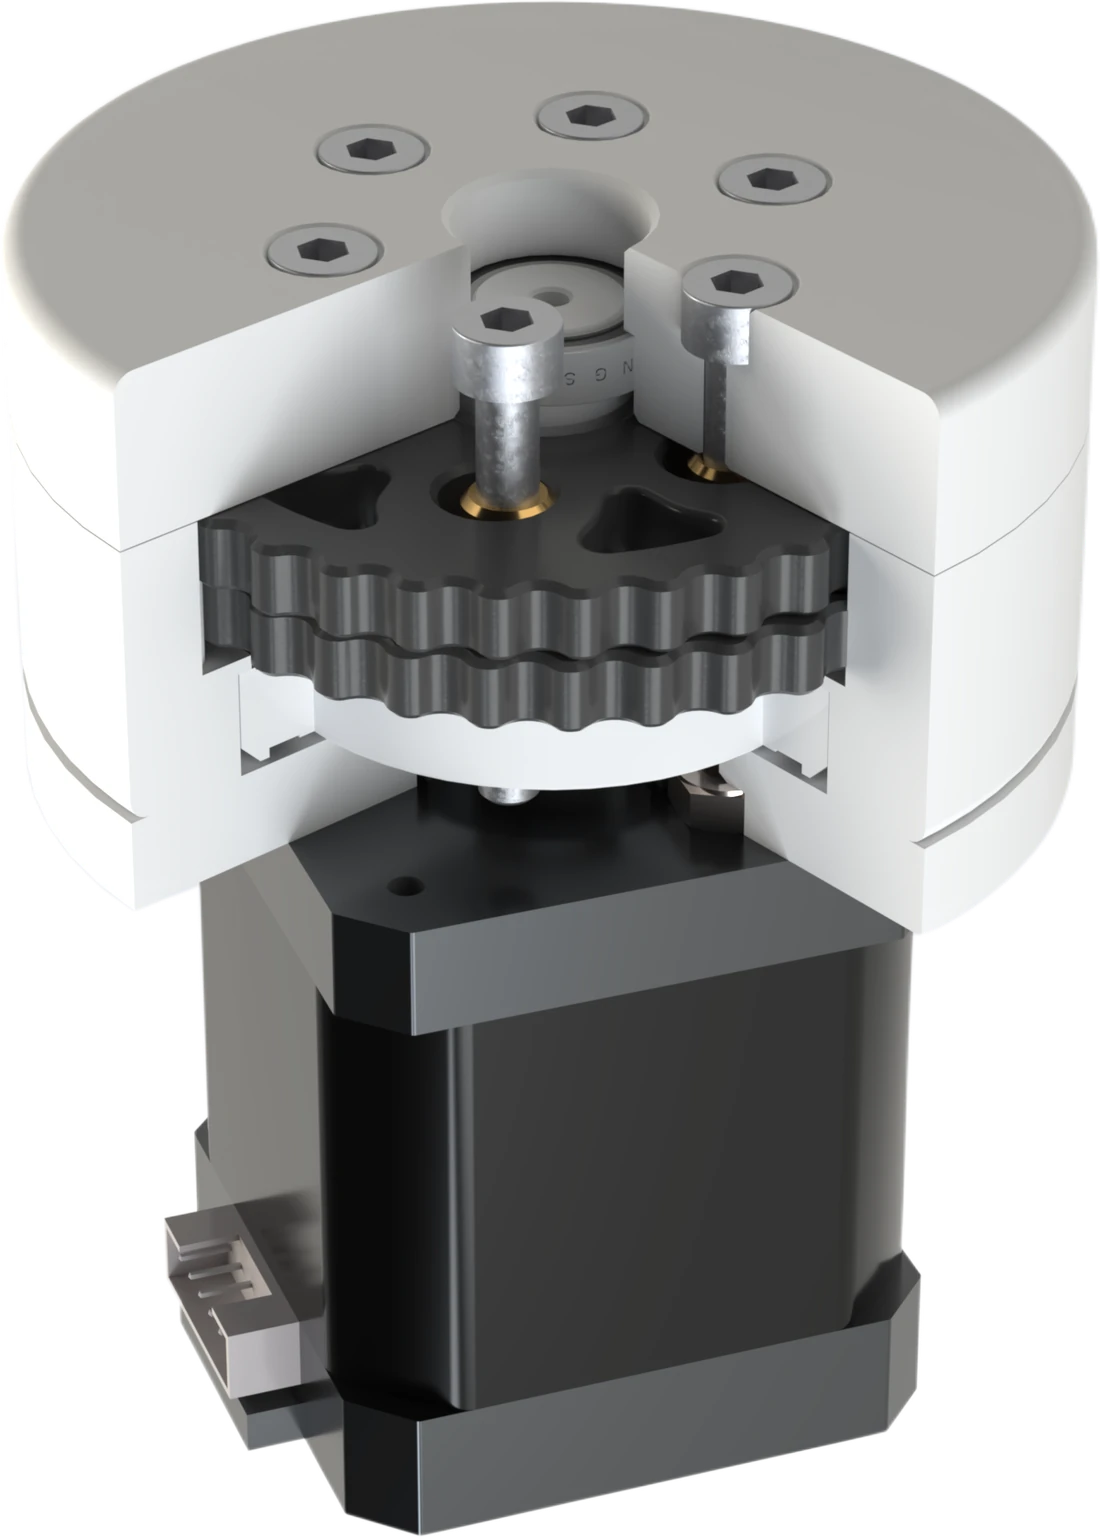 Cycloidal reducer In development33:1, mounts on a NEMA17 motor
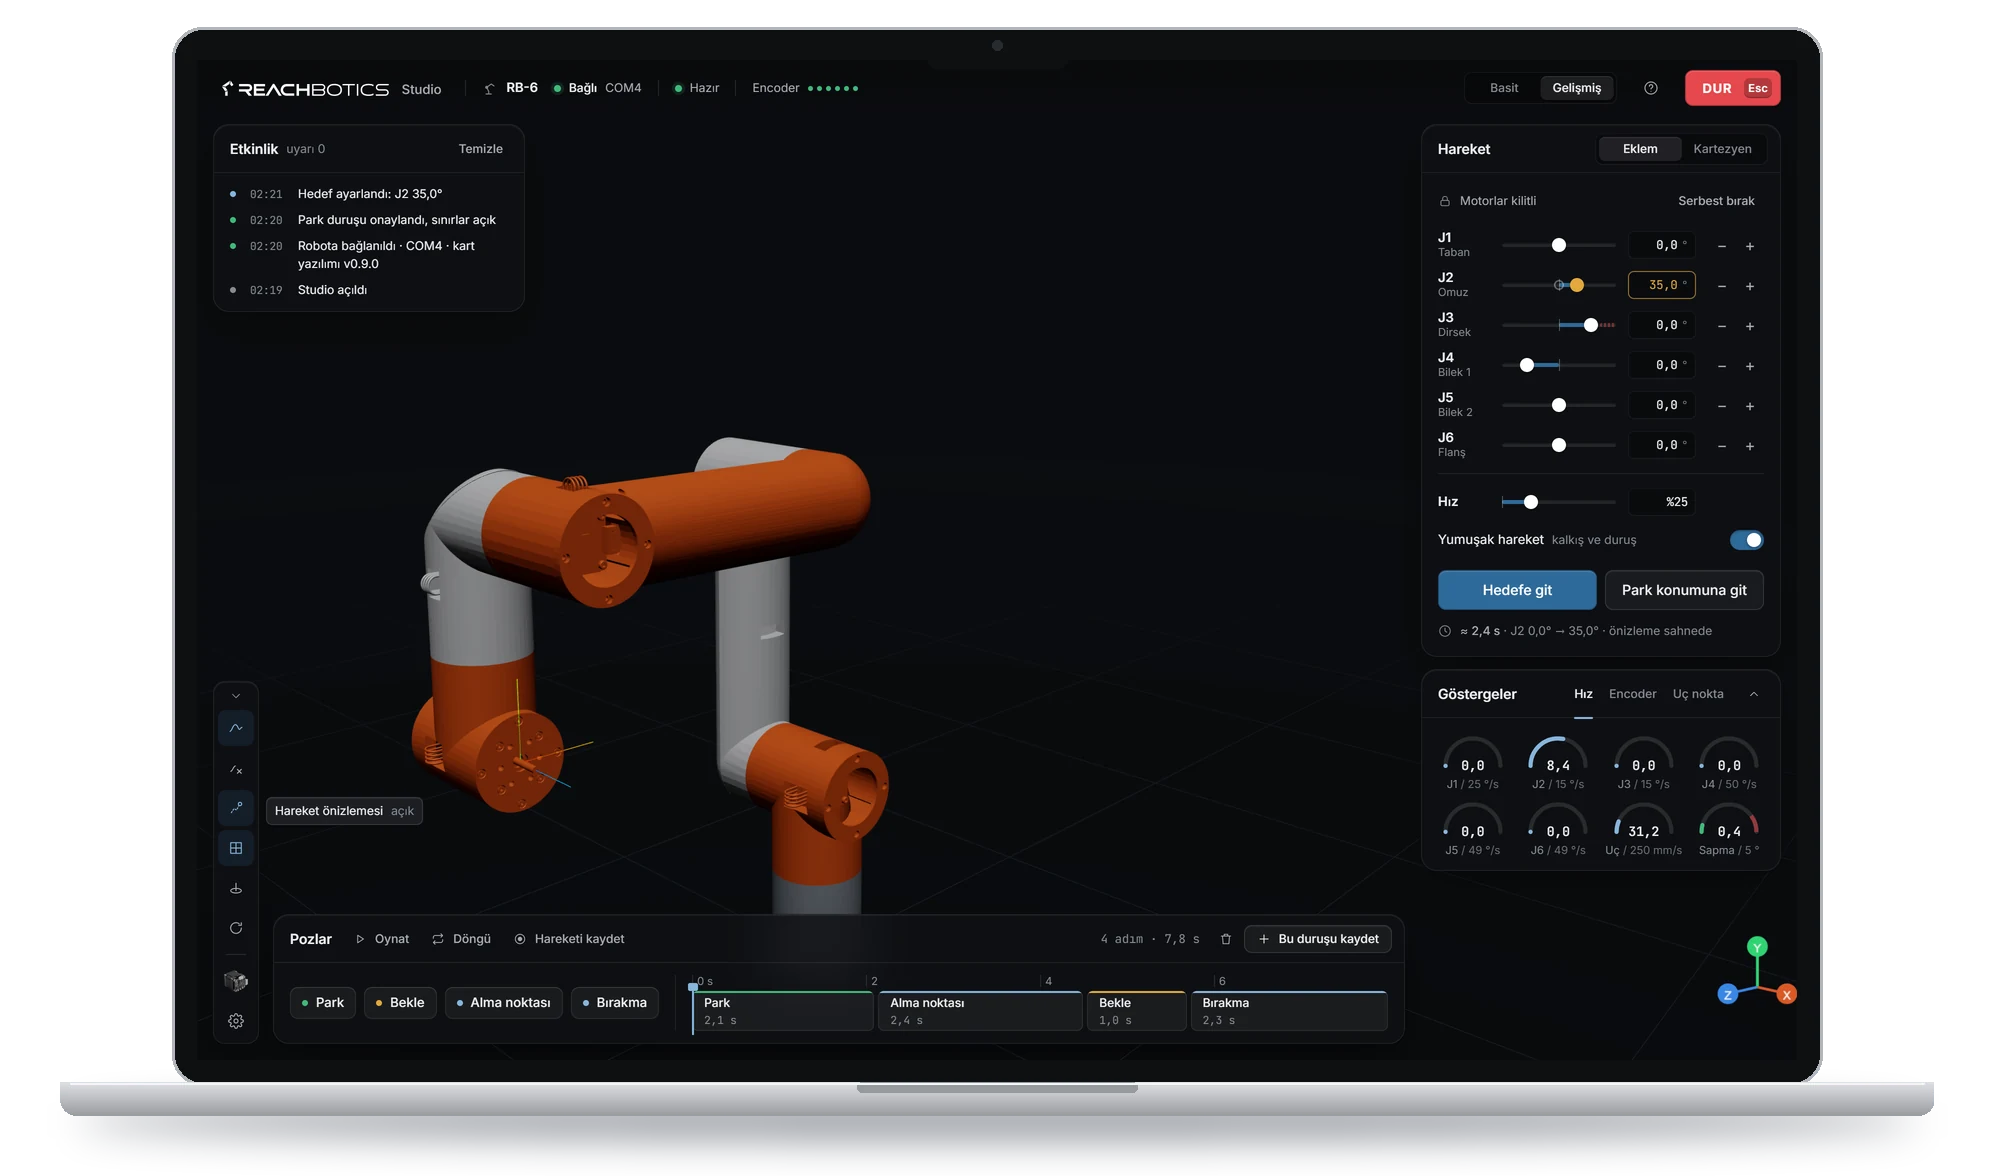 Reachbotics Studio In developmentControl software for Windows
DocumentsPrinting, assembly and electronics guides
All products
Six axes, the same 33:1 cycloidal reducer and a closed-loop motor in every joint.
Explore the RB-6The robot arm, the cycloidal reducer and Reachbotics Studio are in development. Products will be published here when they are ready.
Our products are not on sale yet. We will email you when they are ready.
Each product page has the details. Leave your email if you would like to hear when it is ready.
Every printed part of the six-axis arm, NEMA17 mounts and the assembly order.
The reducer used in every joint of the arm. It prints on a desktop FDM printer and mounts on a NEMA17 stepper.
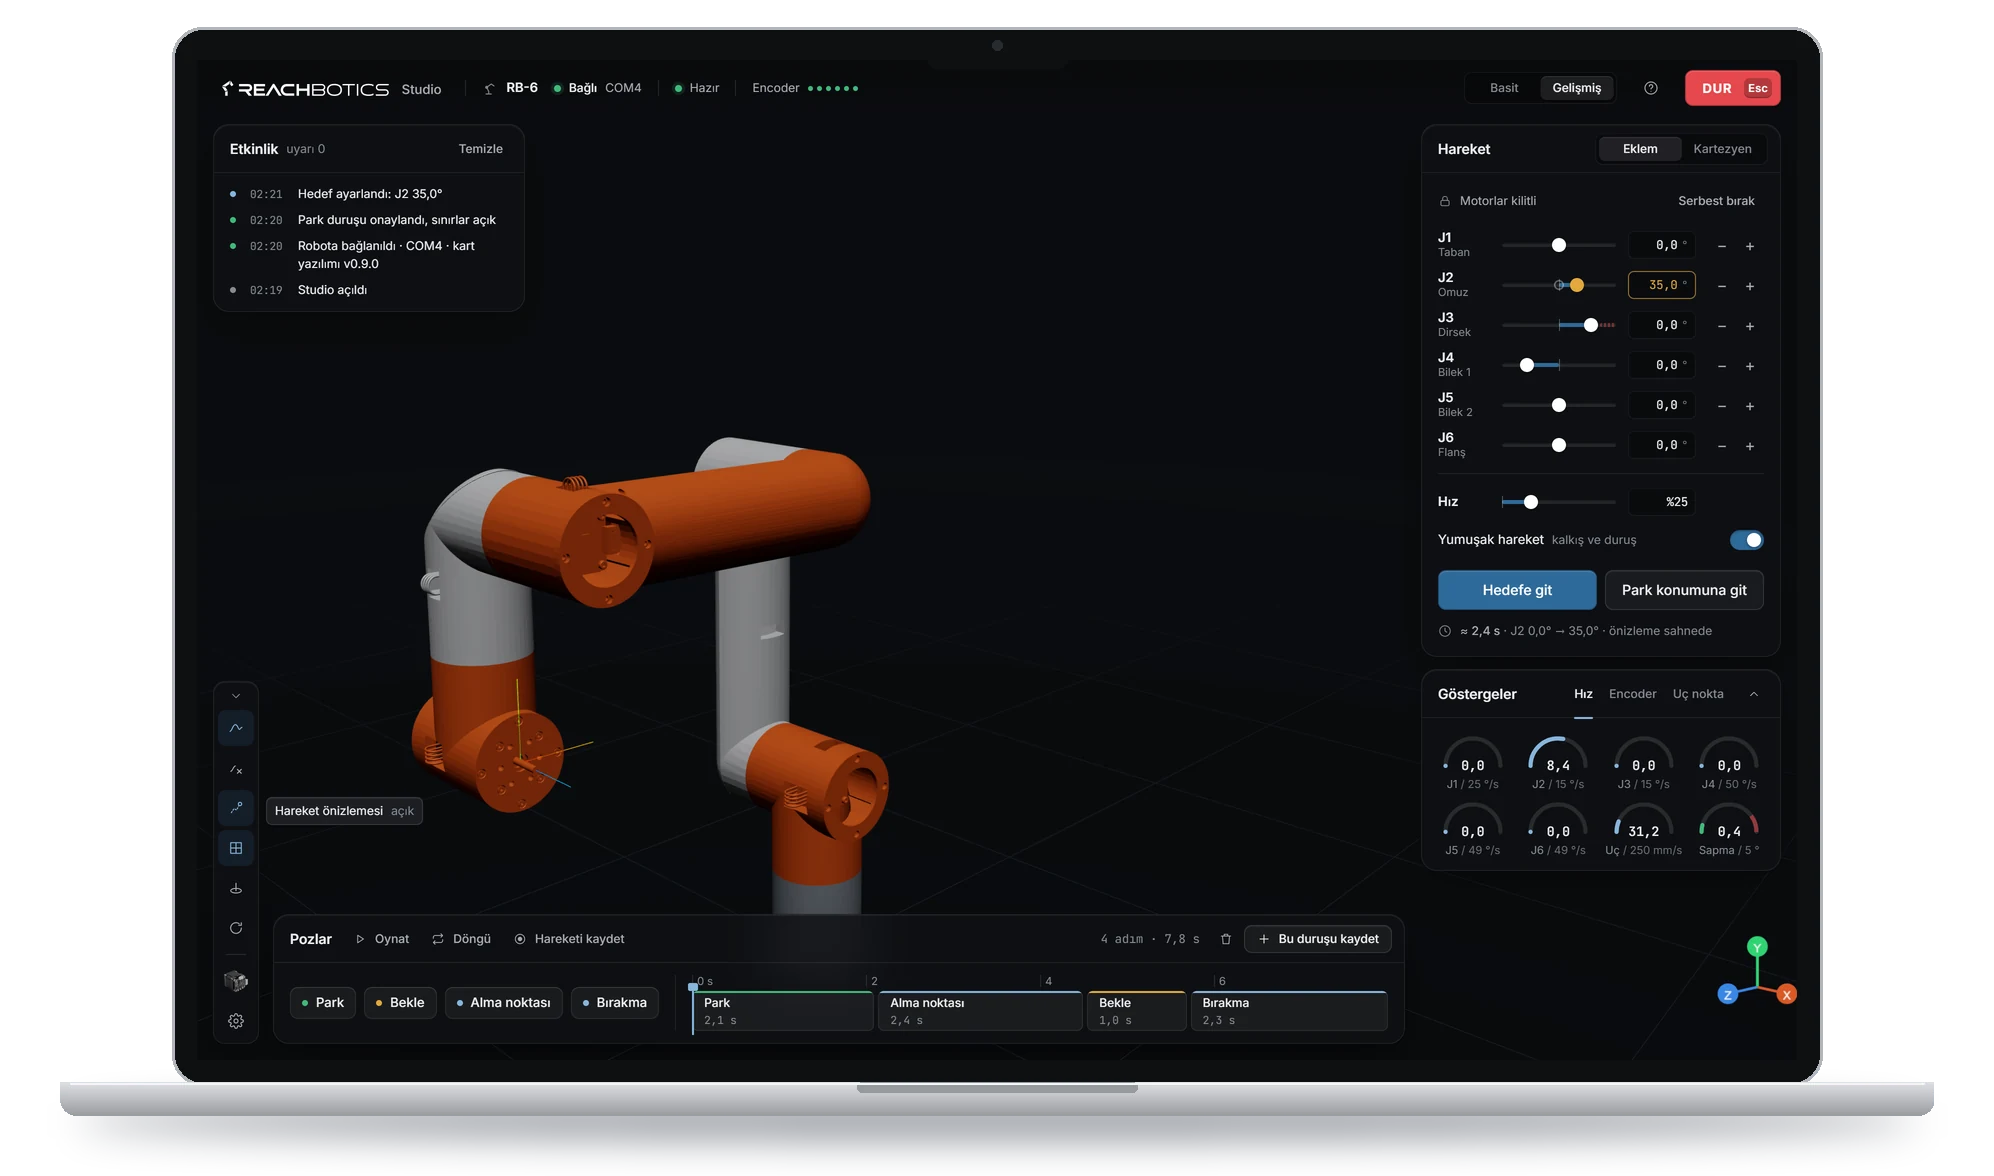
The Windows program that drives the RB-6 from your computer: joint jogging, pose recording and simulation.
| Contents | STL only | STL + STEP |
|---|---|---|
| Printed parts (STL) | ✓ | ✓ |
| Assembly guide (PDF) | ✓ | ✓ |
| Bill of materials (XLSX) | ✓ | ✓ |
| Editable CAD file (STEP) | ✗ | ✓ |
The parts print on a desktop FDM printer, with no machining.
Bearings, fasteners and motors are listed by name, size and quantity.
The STL + STEP option adds the STEP file, so you can adapt the dimensions to your motor.
Reach, payload and repeatability are published once testing is done; we do not guess.
Our products are in development; we will announce the date once it is set. To hear first, leave your email with the “Notify me” button at the top of the page.
An STL file goes straight into the slicer and prints. A STEP file can be edited in CAD programs such as Fusion 360, Onshape and FreeCAD.
The standard license will cover personal, educational and research use. To sell printed parts or use them in client projects, contact us. Details are in the license terms.
The parts are designed for desktop FDM printers. Every part, including the cycloidal discs, prints in PLA. Settings and part orientation are in the print guide.
Leave your email address and we will tell you when the products and Studio are ready.
By submitting, you agree to receive announcement emails under the Privacy Notice; unsubscribe via the link in any email.