From graduation project
to product.
Reachbotics started as a mechatronics graduation project: a six-axis robot arm that can be made on a desktop 3D printer and runs on reducers of our own design. We make the file for every part we design downloadable, so that others can build it too.
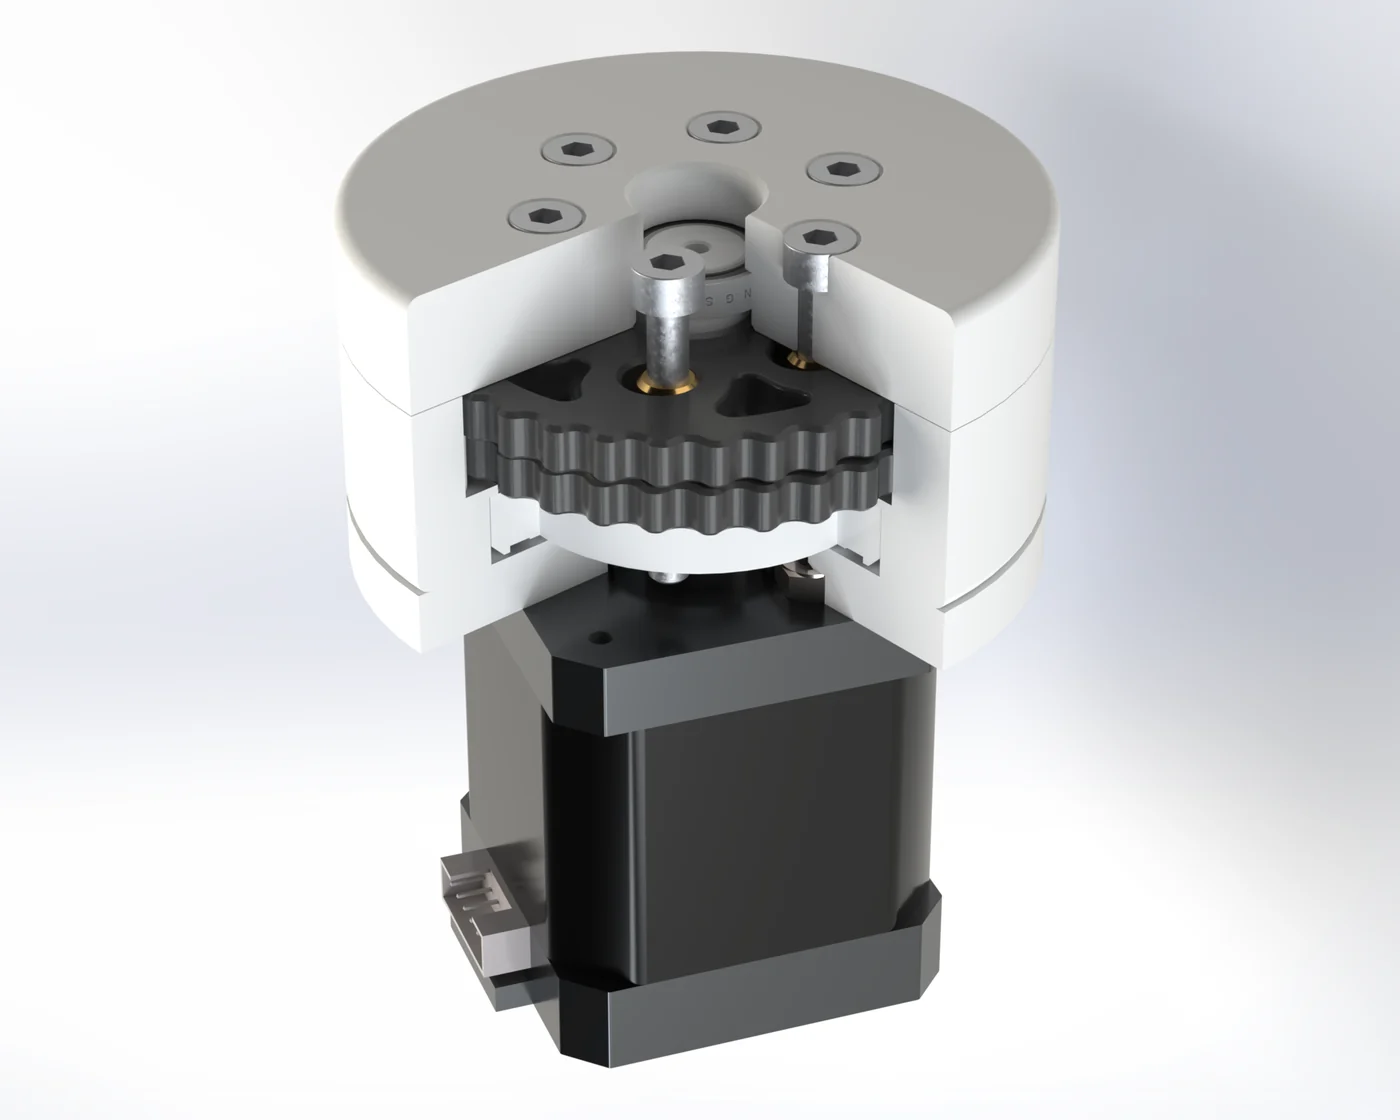
The reducer first, then the arm.
Off-the-shelf robot arms are expensive, and affordable ones are held back by the limits of hobby servo motors. So we started at the heart of the joint: a cycloidal reducer that can be 3D printed. Then we combined six of them into an arm and connected it to our own control board and kinematics software.
- MechanicsA 33:1 cycloidal reducer designed in SolidWorks and a UR-type six-axis arm.
- ElectronicsA six-driver control board for the Arduino Mega and a hardware emergency stop circuit.
- SoftwareForward and inverse kinematics, trajectory planning and a desktop app, written in Python.
What we believe in.
Our packages come with the CAD source; no locked formats or withheld parts.
No machining or custom-made parts; an FDM printer and standard bearings are enough.
Out-of-limit motions are not silently clamped; they are rejected. The emergency stop circuit works independently of the software.
Write to us.
For questions about orders, licensing, business invoices or assembly, fill in the form and we will reply by email.